RIGOR: Rig-Informed Geometry for Omnidirectional Reconstruction
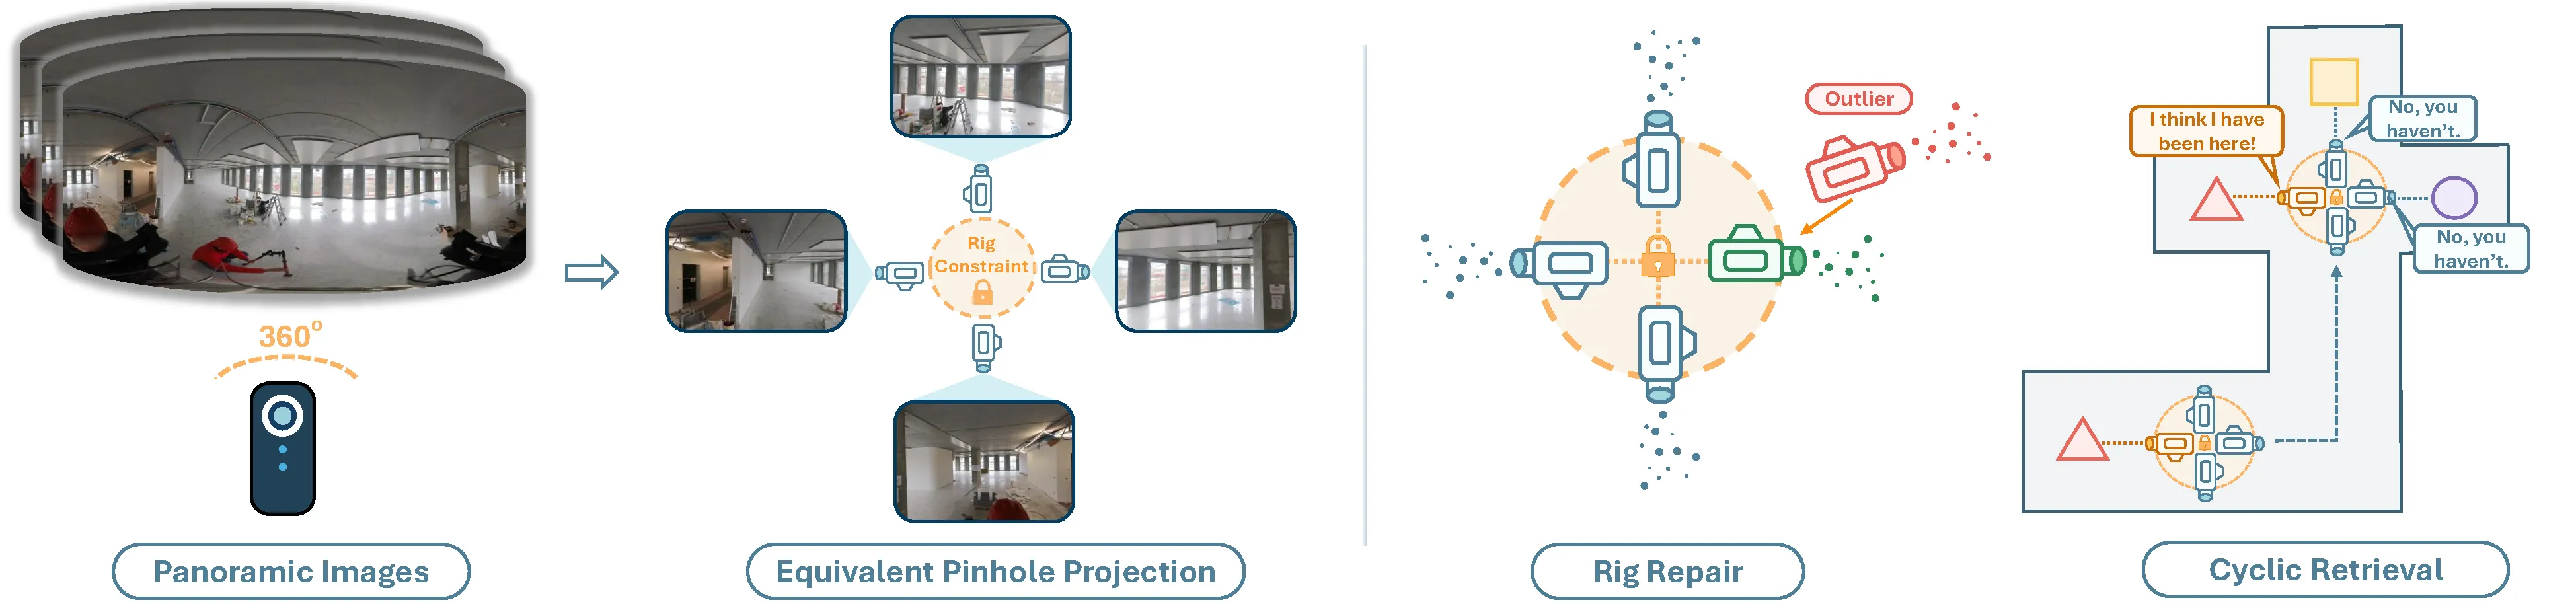
The Problem
Reconstructing large-scale 3D environments from panoramic captures is challenging. Standard perspective-based methods struggle with the wide field of view and scale ambiguities inherent in omnidirectional imagery, while end-to-end panoramic approaches require expensive retraining.
Our Approach
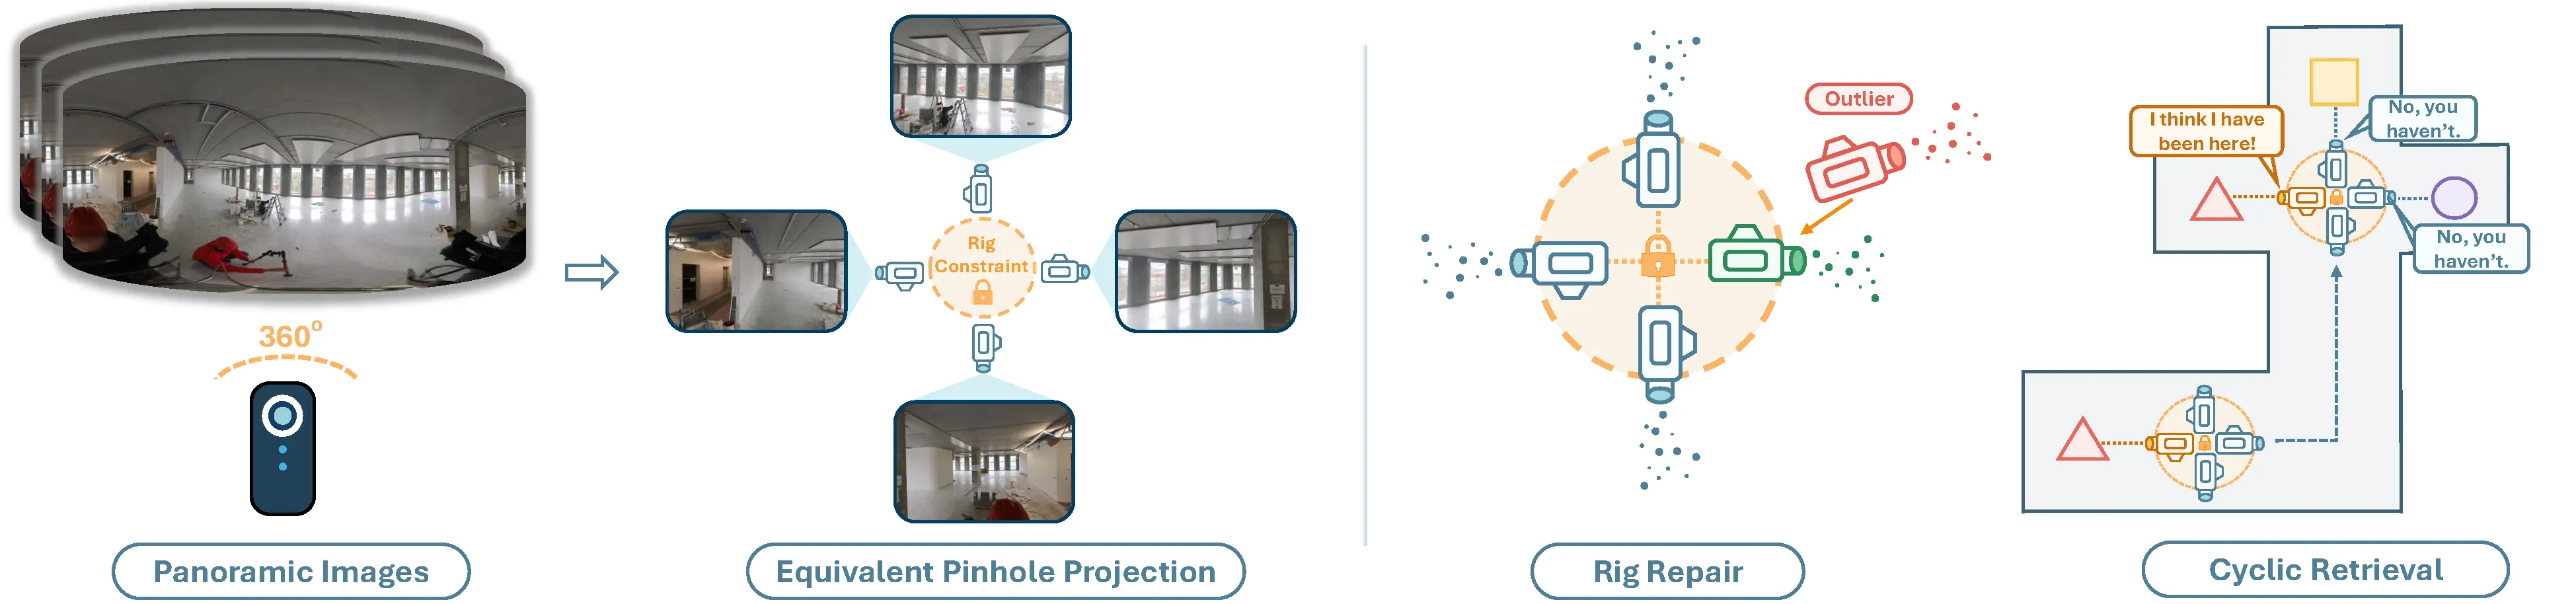
RIGOR treats four perspective views from each panorama as a virtual rig with a shared optical center and known relative orientations. This enables a frozen perspective backbone (no retraining) to be used for long-sequence omnidirectional reconstruction. Key components:
- Rig-informed pose repair - local pointmap and pose correction using the known rig geometry
- Cyclic capture-level loop retrieval - 32-image blocks with 16-image overlap for robust loop closure
- Sim(3) graph optimization - scale-adjusting optimization across the full sequence with frozen learned weights
Results
Evaluated on the Hilti-Trimble-Oxford challenge benchmark (30 runs), RIGOR achieves state-of-the-art reconstruction quality from gravity-aligned panoramas without any fine-tuning of the underlying perspective model.