Help Us Improve Our Website with Cookies
We use cookies to analyze website performance and improve your experience. View Cookie Settings for more information.
About
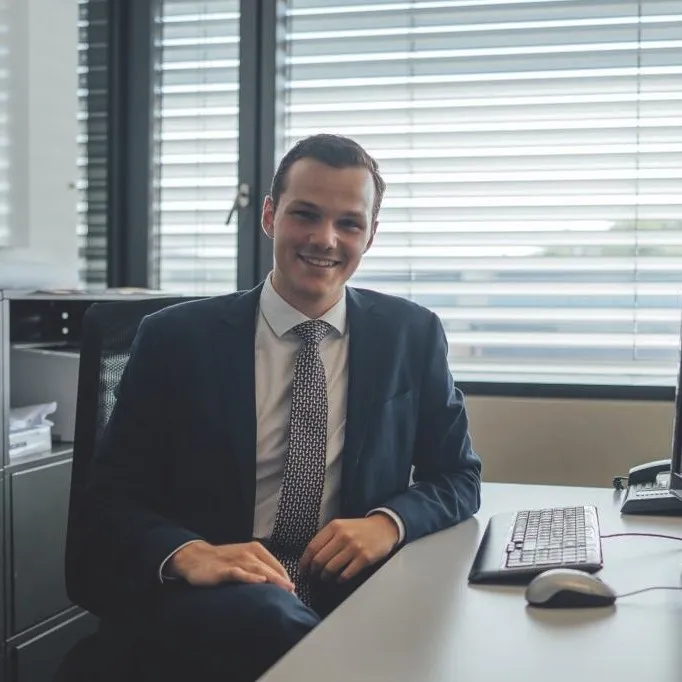
Pietro Bonazzi (born January 30, 1999, in Turin) is a Doctoral Researcher at ETH Zürich in efficient AI, edge machine learning, and embedded systems.
His work spans in-sensor computing, event-based vision, neural network quantization with applications in wearable devices and robotic systems. He has authored 30+ peer-reviewed papers at venues including CVPR, ECCV, NeurIPS, IEEE Sensors, and ICRA, and has received multiple Best Paper Awards and the IEEE Outstanding Lecture Award.
He also lectures at ETH Zürich on Machine Learning on Microcontrollers and co-developed an edX course titled Understanding and Deploying LLMs for Mobile Devices with Arm and the University of Cambridge. He serves as a peer reviewer for CVPR, NeurIPS, IROS, IEEE IoT Journal, and IEEE Sensors Journal.
Hobbies & Outdoors: 🏀🎾🏊♂️🏌️⛵ Played Competitive basketball player for over a decade. Passionate about basketball, tennis, golf and swimming. Currently, studying for an unlimited maritime license for sail and motor boats. Holds the CFA Level I and Swiss standard fishing competence qualification (SaNa).
Experience
ETH Zürich
Huawei
Hewlett Packard Enterprise
valantic
Selected Research Projects in Industry


Latest News
- Oct 2026EFCL ETH ZürichPoster at 3rd EFCL International Workshop on Sustainable AI, ETH Zürich
Presented a poster at the 3rd EFCL International Workshop on Sustainable AI at ETH Zürich, bringing together researchers and industry experts on efficient, scalable, and responsible AI systems.
- Sep 2026IEEE AICASTinyGLASS Presented at IEEE AICAS 2026 in Ha Long Bay, Vietnam
Presented our work on TinyGLASS, a real-time self-supervised in-sensor anomaly detection system, at the 8th IEEE International Conference on AI Circuits and Systems (AICAS) in Ha Long Bay, Vietnam.
- Jul 2026Y CombinatorPresented at YC Startup School 2026 in San Francisco
Selected to attend Y Combinator's Startup School 2026 in San Francisco (July 25–26), a gathering of the world's most promising builders and founders.
- Jul 2026ICVSSPoster at the International Computer Vision Summer School (ICVSS) 2026
Selected to attend the 20th edition of the International Computer Vision Summer School (ICVSS 2026) in Sicily, Italy (July 5–11), themed 'Computer Vision for Spatial and Physical Intelligence'.
- May 2026ETH Zürich D-ITETETH Kite Award 2026
Our team won the ETH Kite Award 2026 for the embedded systems course.
- Jan 2026World Economic ForumWorld Economic Forum 2026 at the USA House, Davos
Attended the World Economic Forum Annual Meeting 2026 in Davos, Switzerland (January 19–23), representing the ETH Zürich startup ecosystem at the USA House.
- Oct 2025IEEE Sensors ConferenceOutstanding Lecture Award IEEE Sensors 2025
Received the Outstanding Lecture Award at IEEE Sensors 2025 in Vancouver for our presentation on in-sensing image segmentation.
- Oct 2025G-ResearchG-Research ETH Zürich Quant Challenge Winner 2025
Our team won the G-Research Quant Challenge at ETH Zürich, a quantitative finance competition focused on cointegration-based trading strategies tested on real-world datasets.
- Oct 2025ETH Zürich D-ITETBest PBL Semester Thesis Award 2025 – PicoSAM2 Image Segmentation
Stefan Zihlmann, one of my students, was awarded for outstanding work on PicoSAM2, a low-latency segmentation system running directly on the Sony IMX500 camera sensor.
- Sep 2025IEEE IWASIBest Paper Award on Event-Based Eye Tracking on STM32N6 at IWASI 2025
At IEEE's Workshop on Advanced Sensors & Interfaces in Puglia, our research on event-based eye tracking using the STM32N6 was awarded Best Paper.
- Jun 2025CVPR 2025Low-Latency FPGA Collision Avoidance with Event Cameras – CVPR 2025
We'll be presenting our FPGA-accelerated obstacle avoidance system using event cameras at the EventVision Workshop during CVPR 2025.
- Oct 2024Swiss-Sino Innovation CenterInvited to Showcase Smart Glasses Across China
Spent 10 days touring Jiangsu, Zhejiang, and Tianjin, unveiling our smart-glasses work and exploring innovation clusters across China's Yangtze River Region.
- Sep 2024ECCV 2024On-Device Object Detection at ECCV Workshop, Milan
Thrilled that our smart glasses object detection work has been accepted for presentation at ICVSE during ECCV 2024 in Milan.
- Jun 2024CVPR 2024New Dataset & System for Event-Based Eye Tracking at CVPR '24
Proud to introduce Retina, our novel event-based eye tracking system and open dataset, at the 1st Workshop on AI for Streaming at CVPR 2024.
- Apr 2024IEEE AICASQ-Segment Accepted at AICAS Conference in Abu Dhabi (UAE)
Our paper was selected for oral presentation at the 6th IEEE AICAS, held at Khalifa University in Abu Dhabi.
- Jan 2024Entrepreneur FirstJoining EF 2024 Cohort in London (UK) to Refine Entrepreneurial Skills
Thrilled to be joining the EF 2024 Cohort! I'll be learning valuable skills to validate entrepreneurial ideas and test co-founder partnerships.
- Nov 2023ImportAI NewsletterGreat Reviews from Anthropic's CEO on our Smart Glass Preprint
Anthropic's CEO discussed TinyissimoYOLO on ImportAI (Jack Clark's newsletter). We'll keep working on the final system to open source hardware and software!
- Oct 2023Hackster.ioPositive Analysis of TinyTracker in ML News
Great to see Nick Bild's insightful analysis of TinyTracker featured on Hackster.io!
- Jun 2023InnovationNetwork.chHardware Innovation Grant from InnovationNetwork.ch
Excited to announce we received a 2k Fr. Grant from InnovationNetwork.ch!
- Dec 2022Nova TalentFeatured in the Nova Talent Italian List 2022
Honored to be invited to the Gala organized by Bocconi University for being included in the Nova Talent Italian List 2022 for Computer Science.
- 2023UZH / Google ResearchFew-Shot Point Cloud Reconstruction and Denoising
Excited to share my work on few-shot point cloud reconstruction and denoising using learned Gaussian splats and fine-tuned diffusion features, part of the Robotics & Perception Group (UZH) and Google Inc.
- 2023UZH / Google Research3D Scene Generation from Scene Graphs
Proud to present our project on 3D scene generation from scene graphs and self-attention, developed with the Robotics & Perception Group (UZH) and Google Inc.